Configure Now
Items in Your Cart0
0Items in Your Cart
Start building your packageShop Now
Dead Reckoning navigation, also known as "deduced reckoning," relies on the principle of estimating the current position based on the last known position, velocity, and heading. It involves using the direction and speed of movement to calculate where you are now relative to where you were previously.
Dead Reckoning is particularly useful in scenarios where GPS signals are unreliable or unavailable, such as underwater environments where GPS signals cannot penetrate. This method has been integral to navigation, serving as a reliable means of orientation when other references are unavailable or unreliable.
“Dead reckoning is quickly becoming our new favorite way to operate underwater ROVs and understand positioning of our vehicles,” says Sam Macdonald, President, Deep Trekker. “Setting up USBL or flying completely blind is hard for us as users and our customers. We want to make the piloting experience as easy as possible.”
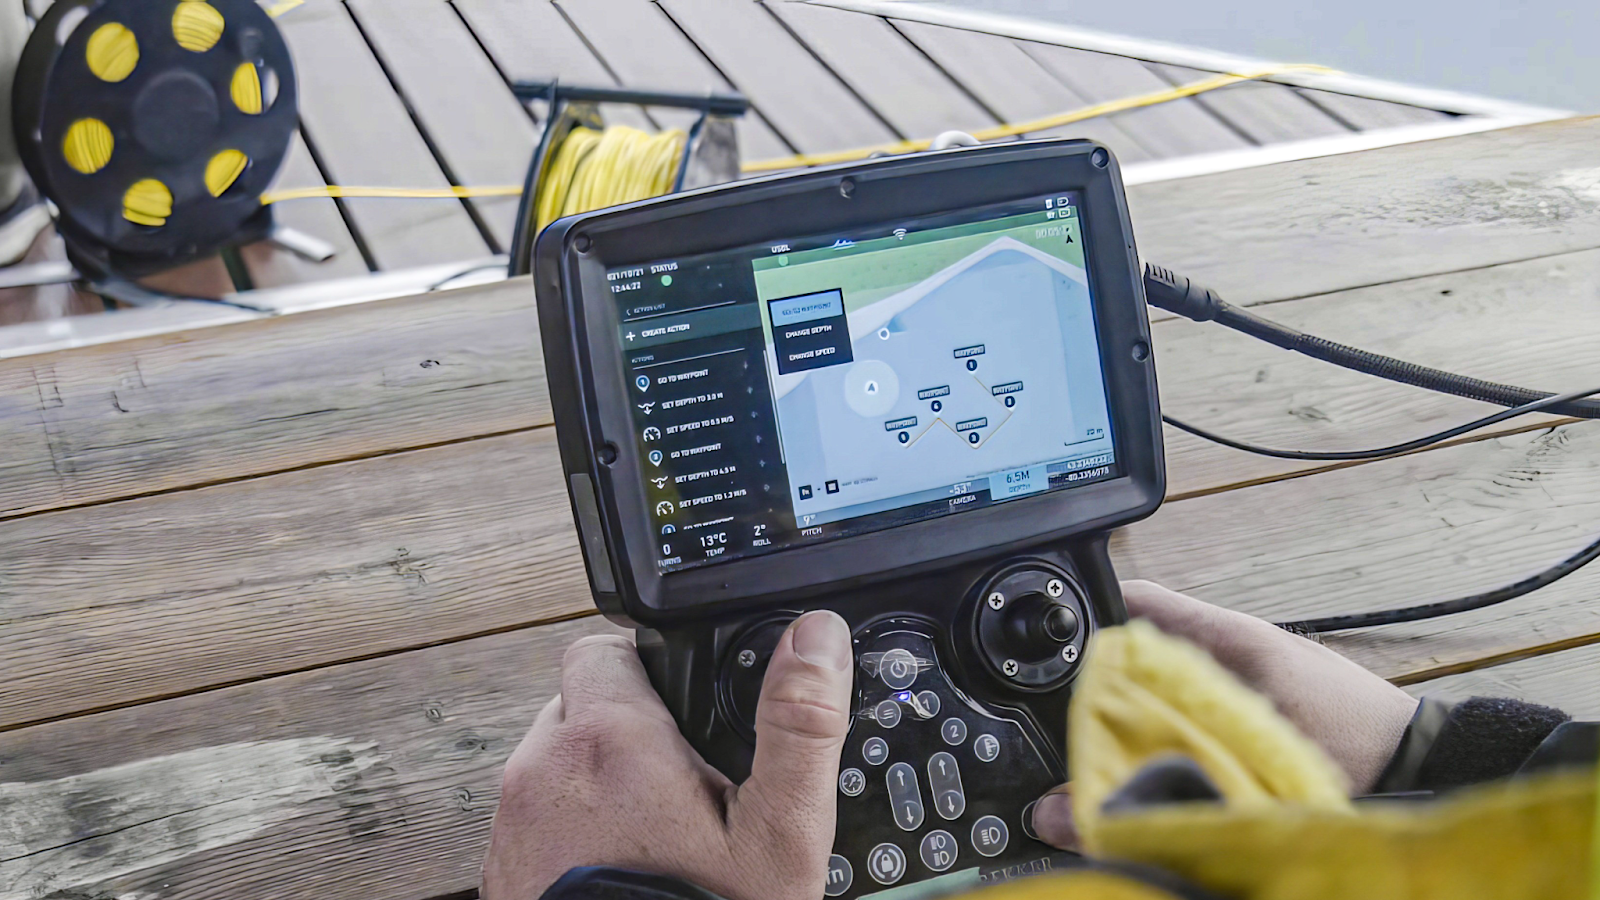
There are numerous challenges with underwater navigation. Unlike terrestrial or aerial navigation, where landmarks or satellites provide reference points, underwater environments offer minimal visual cues.
Factors such as fluctuating ocean currents, variations in water density, and unpredictable underwater terrain further complicate the navigation challenges. Without reliable navigation, underwater vehicles run the risk of veering off course, potentially endangering both the vehicle itself and any onboard equipment or personnel.
Navigating underwater environments poses distinct challenges, requiring specialized techniques like Dead Reckoning to ensure safe and efficient operations. Underwater navigation lacks prominent landmarks or GPS signals, making reliance on Dead Reckoning a key method for underwater positioning.
This method, reminiscent of long-standing historical navigation practices, becomes particularly important in underwater operations where traditional navigation aids like landmarks or celestial bodies are inaccessible.
Understanding and implementing Dead Reckoning involves leveraging advanced sensors and algorithms to mitigate inherent challenges, such as sensor inaccuracies and cumulative drift. As technology progresses, optimizing Dead Reckoning capabilities becomes pivotal for enhancing underwater navigation.
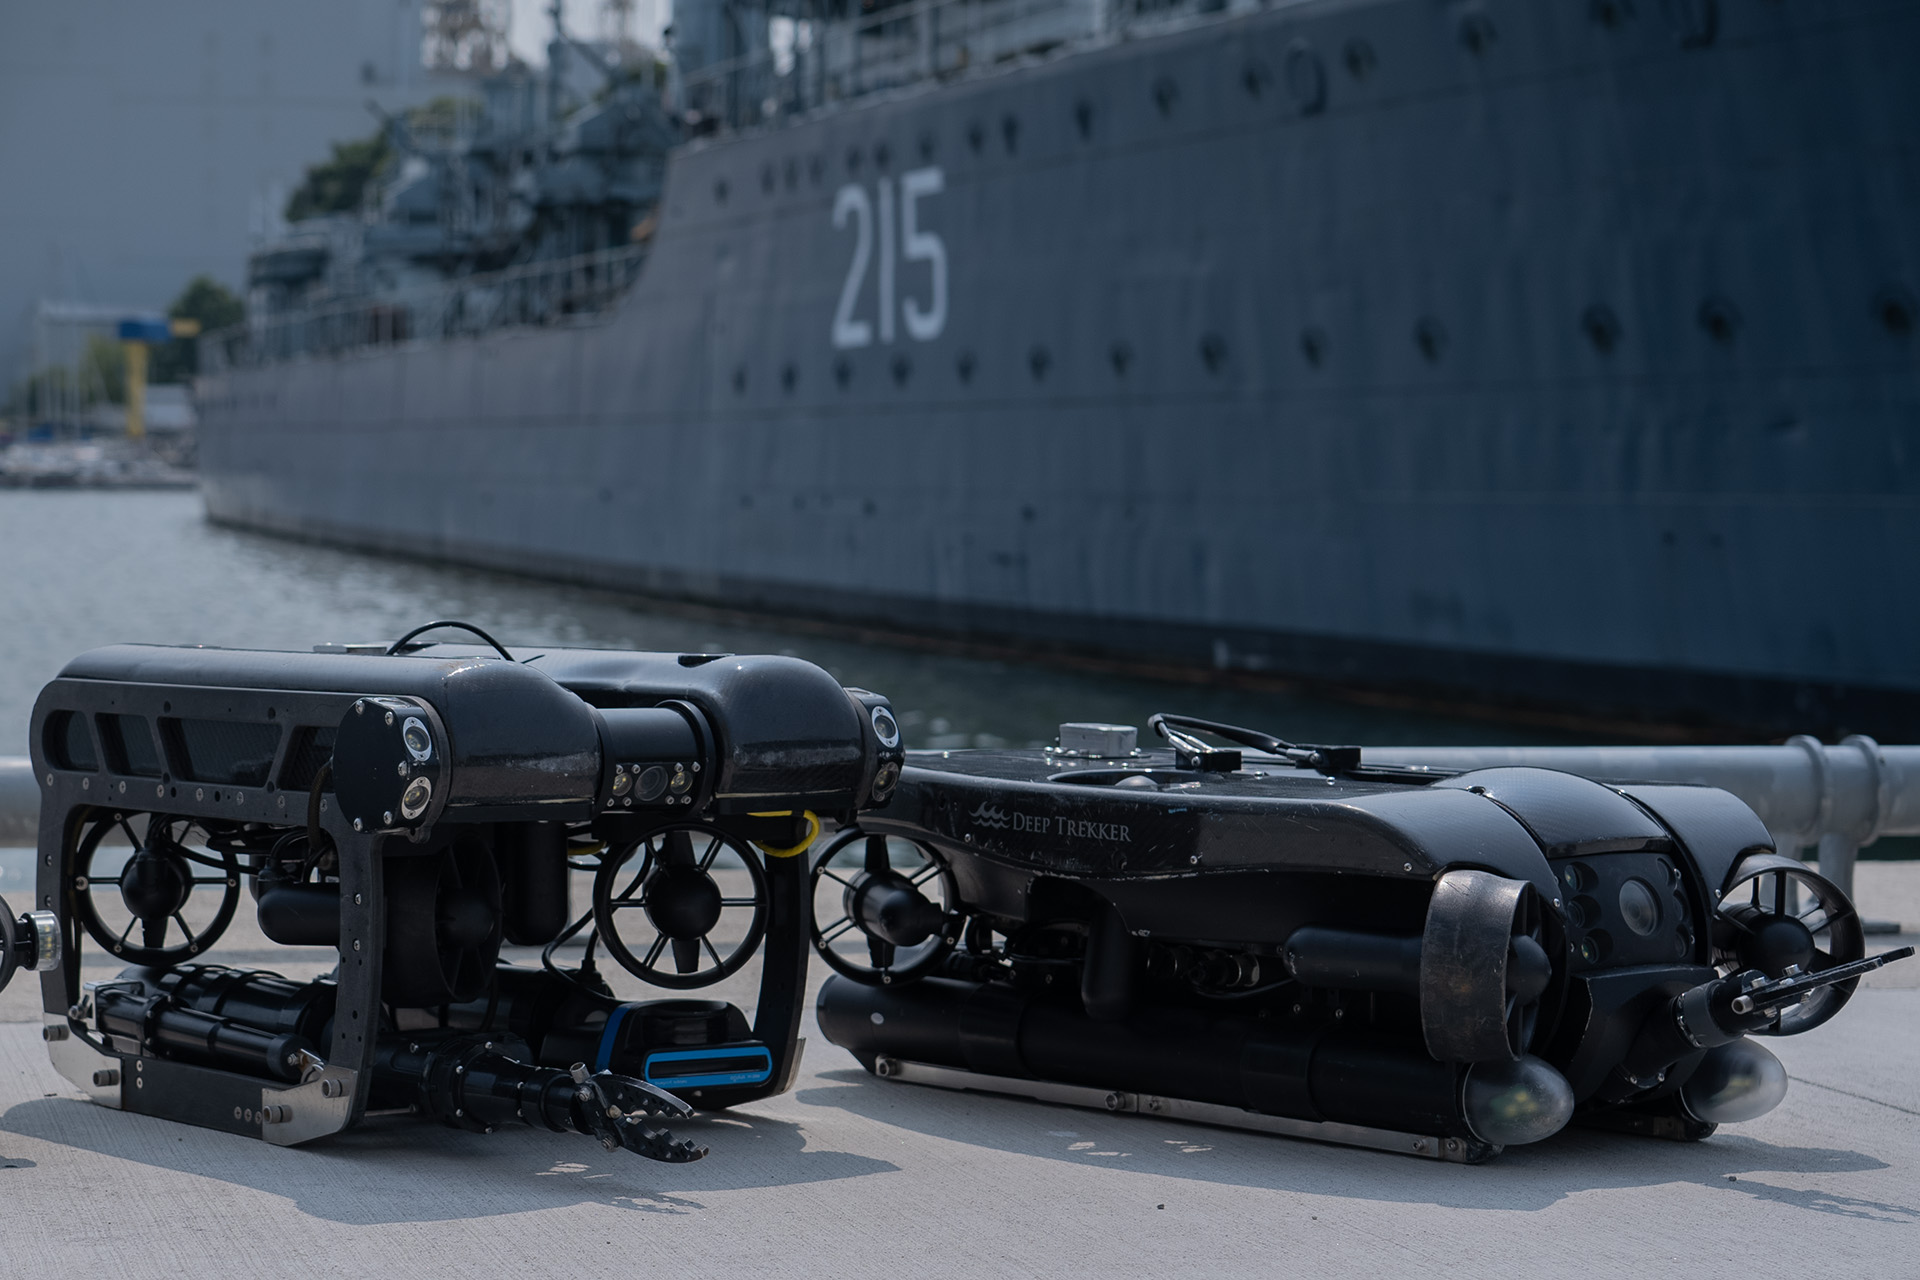
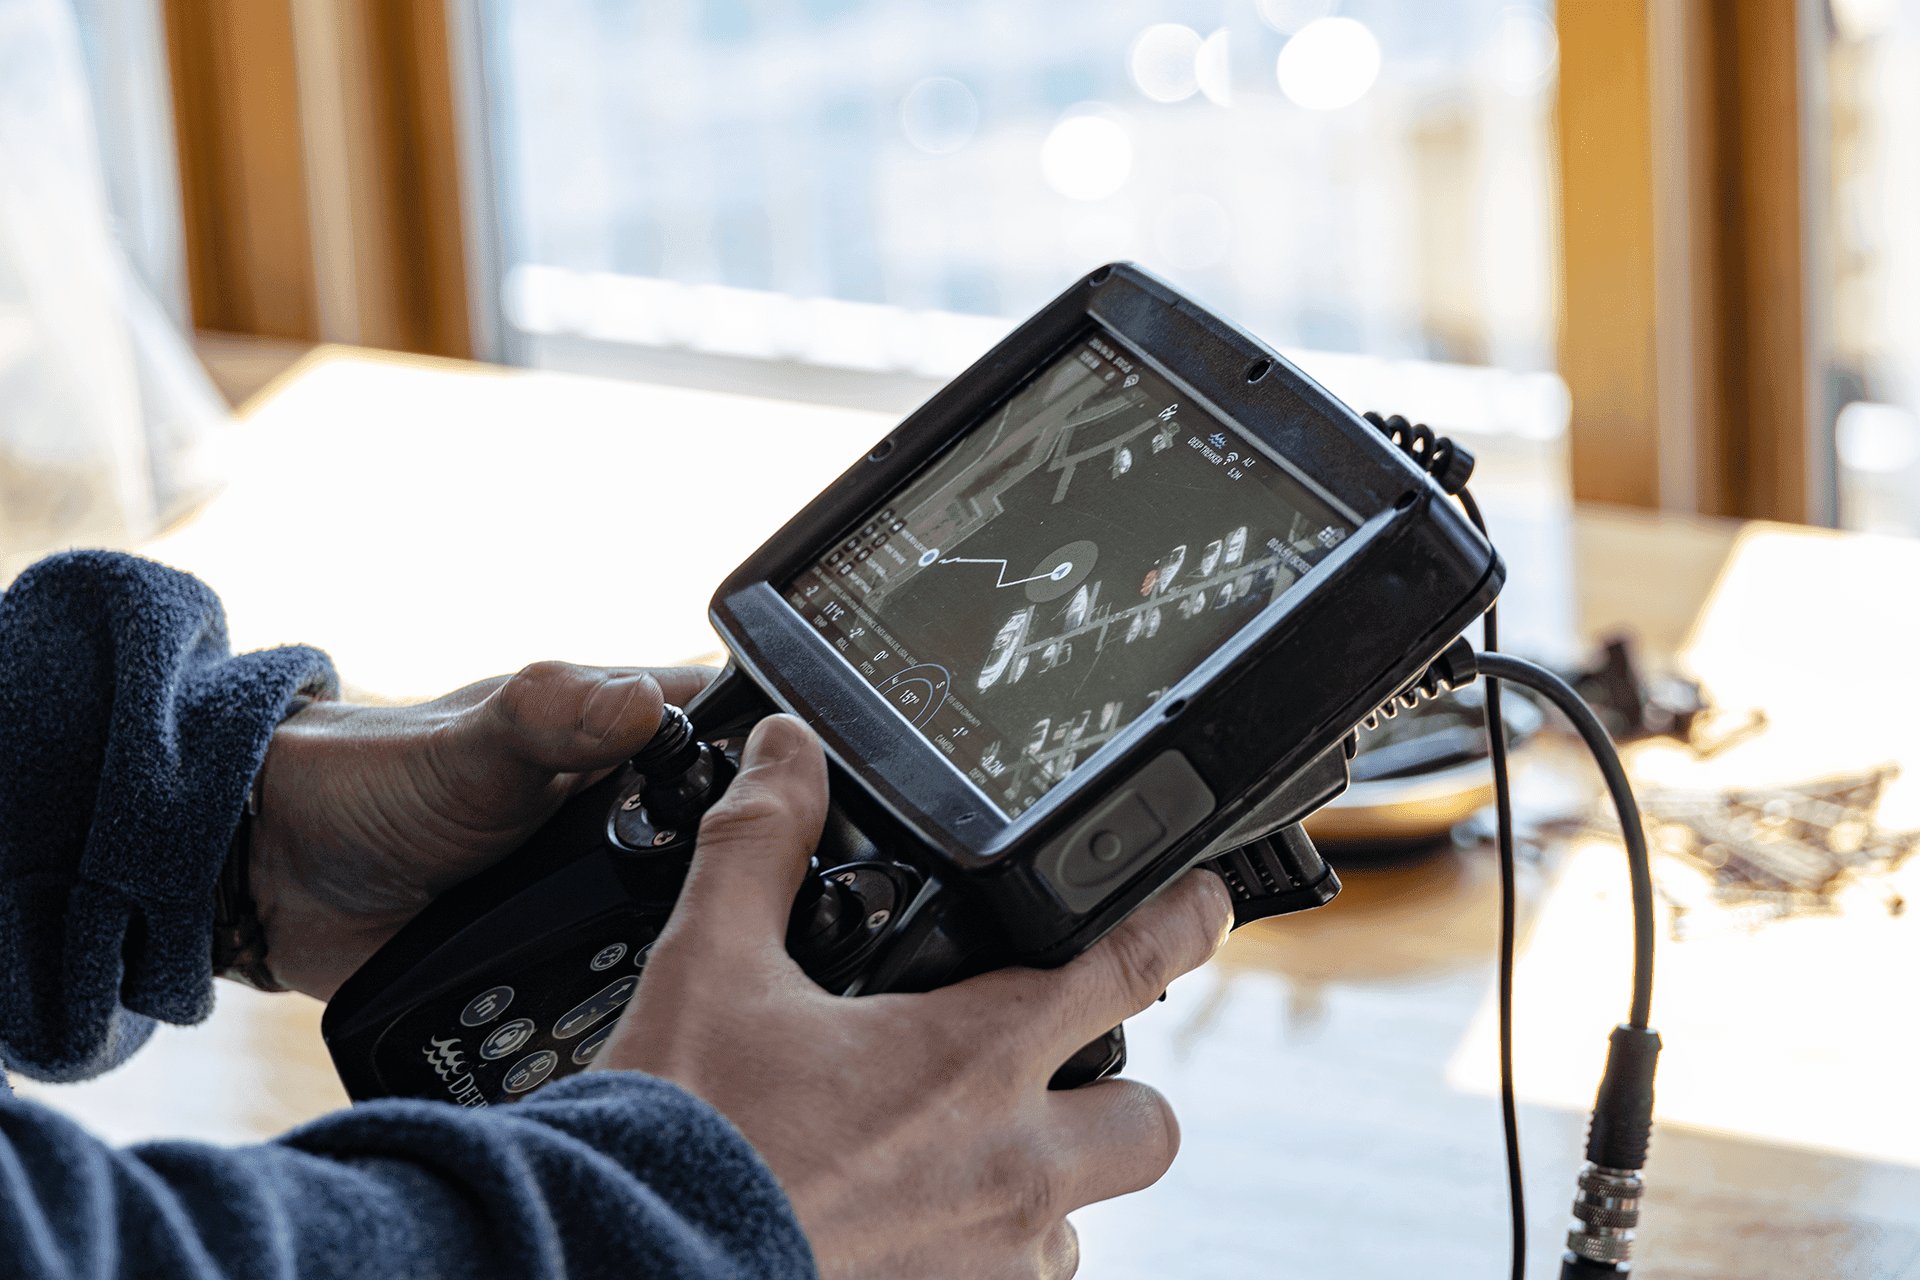
Deep Trekker’s PIVOT and REVOLUTION ROVs can operate with Dead Reckoning utilizing an upgraded inertial measurement unit (IMU) and Doppler Velocity Log (DVL) sensor combined with our BRIDGE software. The goal of these underwater ROV systems is to simplify the experience so customers can input an initial position and then get in the water and go. That doesn’t mean there aren’t any best practices you can leverage to optimize your experience! Below are some tips and tricks to assist with your ROV piloting.
The 6 Rules of Dead Reckoning are guidelines used in navigation, particularly in maritime and aviation contexts, to ensure that an estimated position (Dead Reckoning position) remains as accurate as possible throughout a journey. These rules help navigators keep track of their position and make necessary adjustments. To effectively maintain the vessel’s Dead Reckoning position, the navigator should follow these 6 rules:

1. Regular Position Updates: Update the Dead Reckoning position at regular intervals, typically every hour on the hour. This helps account for changes in speed, course, and environmental conditions that may affect the estimated position. This periodic recalibration is essential for compensating for sensor drift, especially prevalent in underwater technology. Manual recalibration or resurfacing with GPS helps in correcting any deviations and maintaining accuracy.
2. Adjustment after course changes: Following any alteration in the vehicle's course, promptly update the Dead Reckoning position to accommodate the modified trajectory. Utilize additional sensors such as a Doppler Velocity Log (DVL) sensor that tracks changes from the seafloor for underwater vehicles or Inertial Measurement Unit (IMU) sensors that track vehicle orientation changes to ensure alignment with the intended route.
3. Adjustment after speed changes: Whenever there is a change in the vehicle's speed, it's also important to update the Dead Reckoning position immediately to help ensure that the calculated position remains accurate, considering the altered velocity.
4. After every fix or running fix: A "fix" is a position obtained from external references, such as celestial observations, GPS, or terrestrial landmarks. A "running fix" is an ongoing series of fixes that helps refine the Dead Reckoning position. After obtaining either a fix or running fix, the navigator should update the Dead Reckoning position to incorporate this more accurate position information. In the case of an ROV, running fixes could be a GPS mounted on top that gets a fix whenever surfacing or a USBL getting pings during its dive. A fix also could be from a manual GPS input by the user when the ROV surfaces.
5. After plotting a single line of position: A line of position is a navigational line that represents the possible positions of a vehicle at a specific time. It is determined using observations of celestial bodies, radar ranges, or other means. After plotting a single line of position, the navigator should update the Dead Reckoning position to account for this new piece of positional data.
6. DR twice and label with Course and Speed: After every fix or running fix (repeated for emphasis). Reiterating the importance of updating the Dead Reckoning position after obtaining a fix or running fix. This ensures that the Dead Reckoning position continuously incorporates the most accurate position information available.
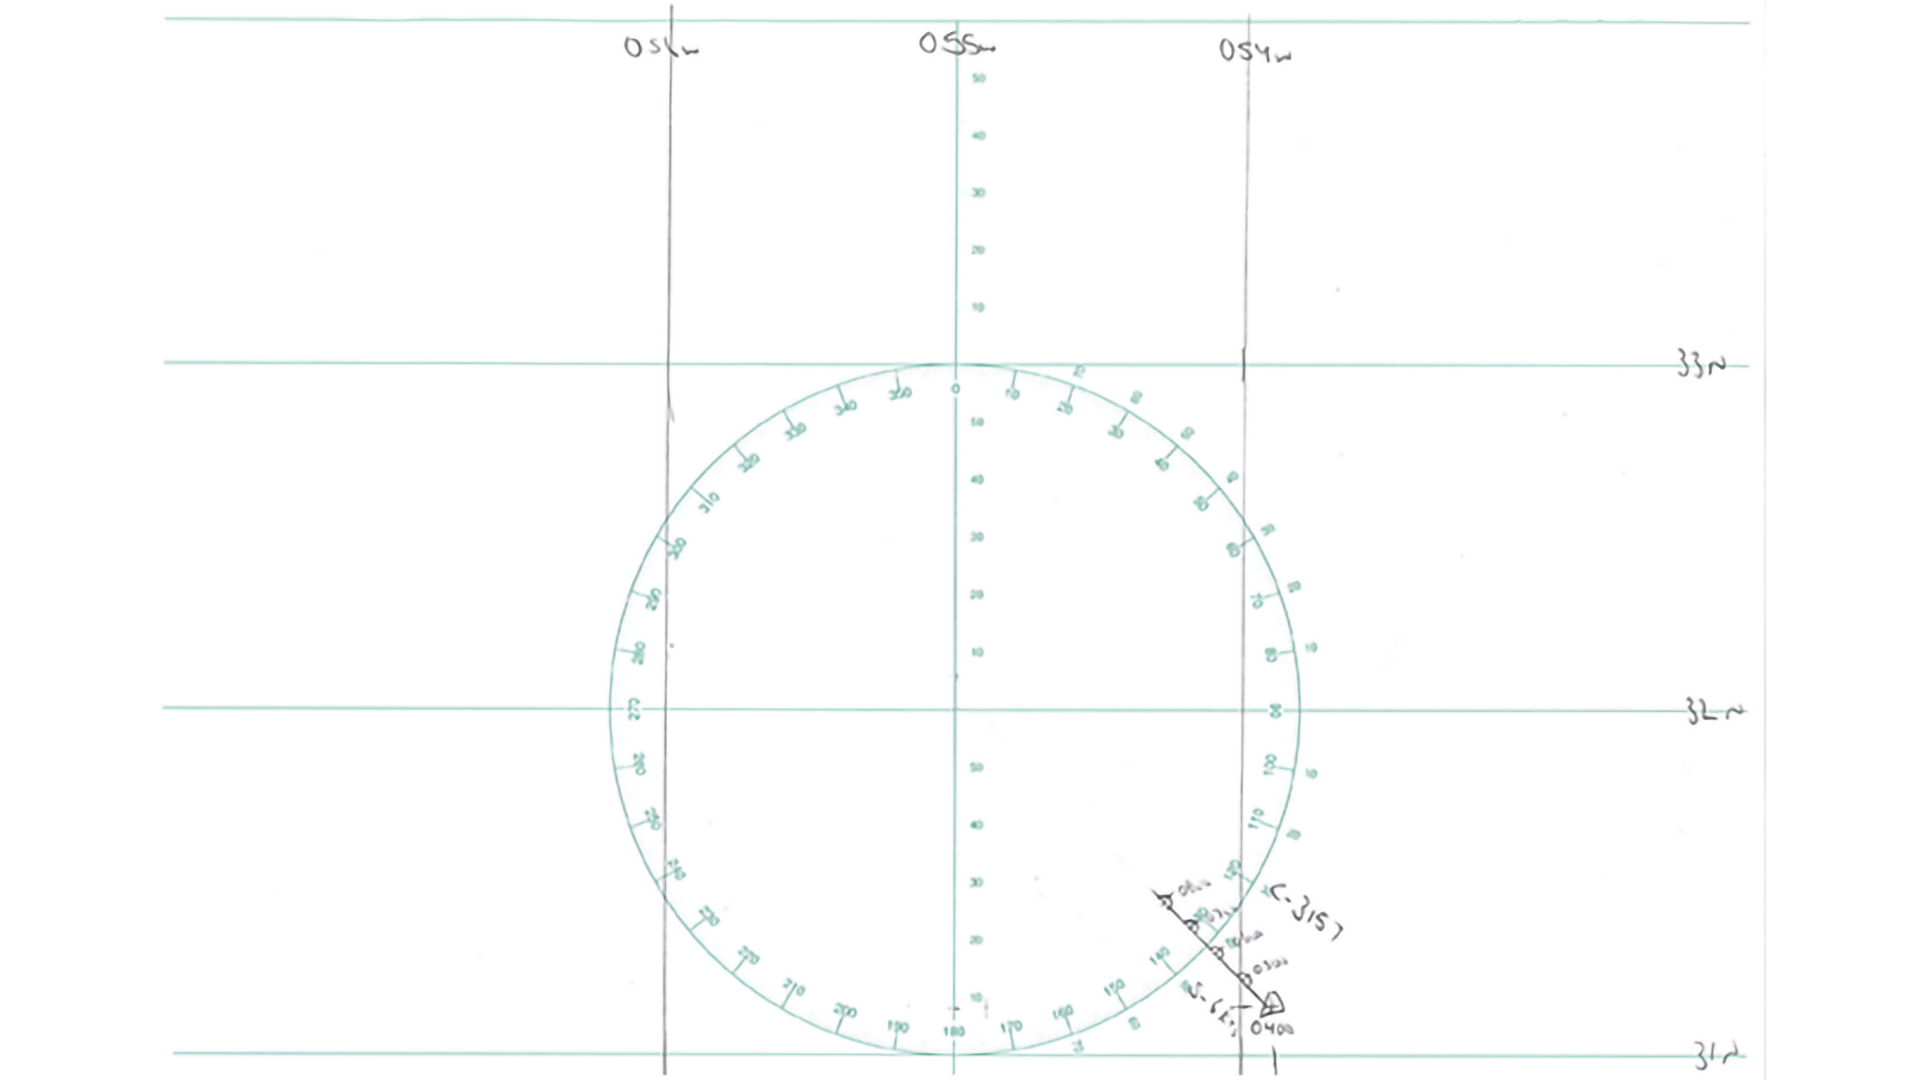
Fig. 1: Example of a Mercator chart style Universal Plotting Sheet used by the Navy for navigation.
Discover how Deep Trekker's ROV technology transforms underwater navigation, overcoming traditional challenges in underwater positioning.
Sensors play a significant role in Dead Reckoning by providing essential data inputs for calculating position estimates. Particularly in underwater navigation scenarios with ROVs, characterized by limited visual references, sensors serve as the eyes and ears of the vehicle, capturing crucial information about its movement and surroundings.
Various types of sensors are employed to track different aspects of the vehicle's motion. Doppler Velocity Log (DVL) sensors measure the vehicle's velocity relative to the seafloor by analyzing Doppler shifts in acoustic signals. This data is integral for calculating speed and direction changes, forming the basis of Dead Reckoning calculations. Additionally, Inertial Measurement Unit (IMU) sensors track the vehicle's orientation and angular velocity, providing necessary inputs for maintaining course accuracy.
Advancements in sensor technology, such as miniaturization and improved accuracy, have also enabled more sophisticated Dead Reckoning systems. MEMS (Micro-Electro-Mechanical Systems) sensors, characterized by their compact size and low power consumption, have become increasingly prevalent, offering a perfect blend of performance and efficiency for underwater navigation applications.
By leveraging the capabilities of these sensors, Dead Reckoning systems can navigate with improved precision, overcoming the challenges posed by the underwater environment and enabling safer and more efficient navigation.
Long before electronic sensors, divers relied on dead reckoning to find their way back to an entry point in low visibility. The method used underwater today is the same one: track heading, speed, and time to estimate position without external references.

A diver navigating by dead reckoning holds a compass heading, counts kick cycles or times each leg to gauge distance, and logs every turn so the route can be reversed on the way back. Success depends on disciplined tracking rather than landmarks, which are often invisible in turbid water.
The same principle scales to remotely operated vehicles. Where a diver counts kicks, an ROV measures velocity with a Doppler Velocity Log (DVL) and orientation with an inertial measurement unit (IMU), then updates its estimated position continuously through Dead Reckoning.
For teams that work alongside ROVs on commercial diving operations, that shared logic makes the vehicle's navigation easy to follow and trust: the same technique divers already know, applied automatically and logged for repeatable, documented positioning.
Explore advanced underwater navigation tech with Deep Trekker ROVs. Learn about MEMS and FOG IMU, Dead Reckoning, and USBL integration for precise positioning.
While Dead Reckoning serves as a valuable navigation technique, it is not without its challenges and limitations. Understanding these factors is important for mitigating risks and optimizing the performance of Dead Reckoning systems.
One notable challenge is the accumulation of errors over time, often referred to as "dead reckoning drift". This drift can arise from sensor inaccuracies, environmental disturbances, and uncertainties in the vehicle's dynamics. It’s important to note that these errors can compound, leading to considerable deviations from the true position, which is why periodic updates and recalibrations are so critical for maintaining accurate positional data.
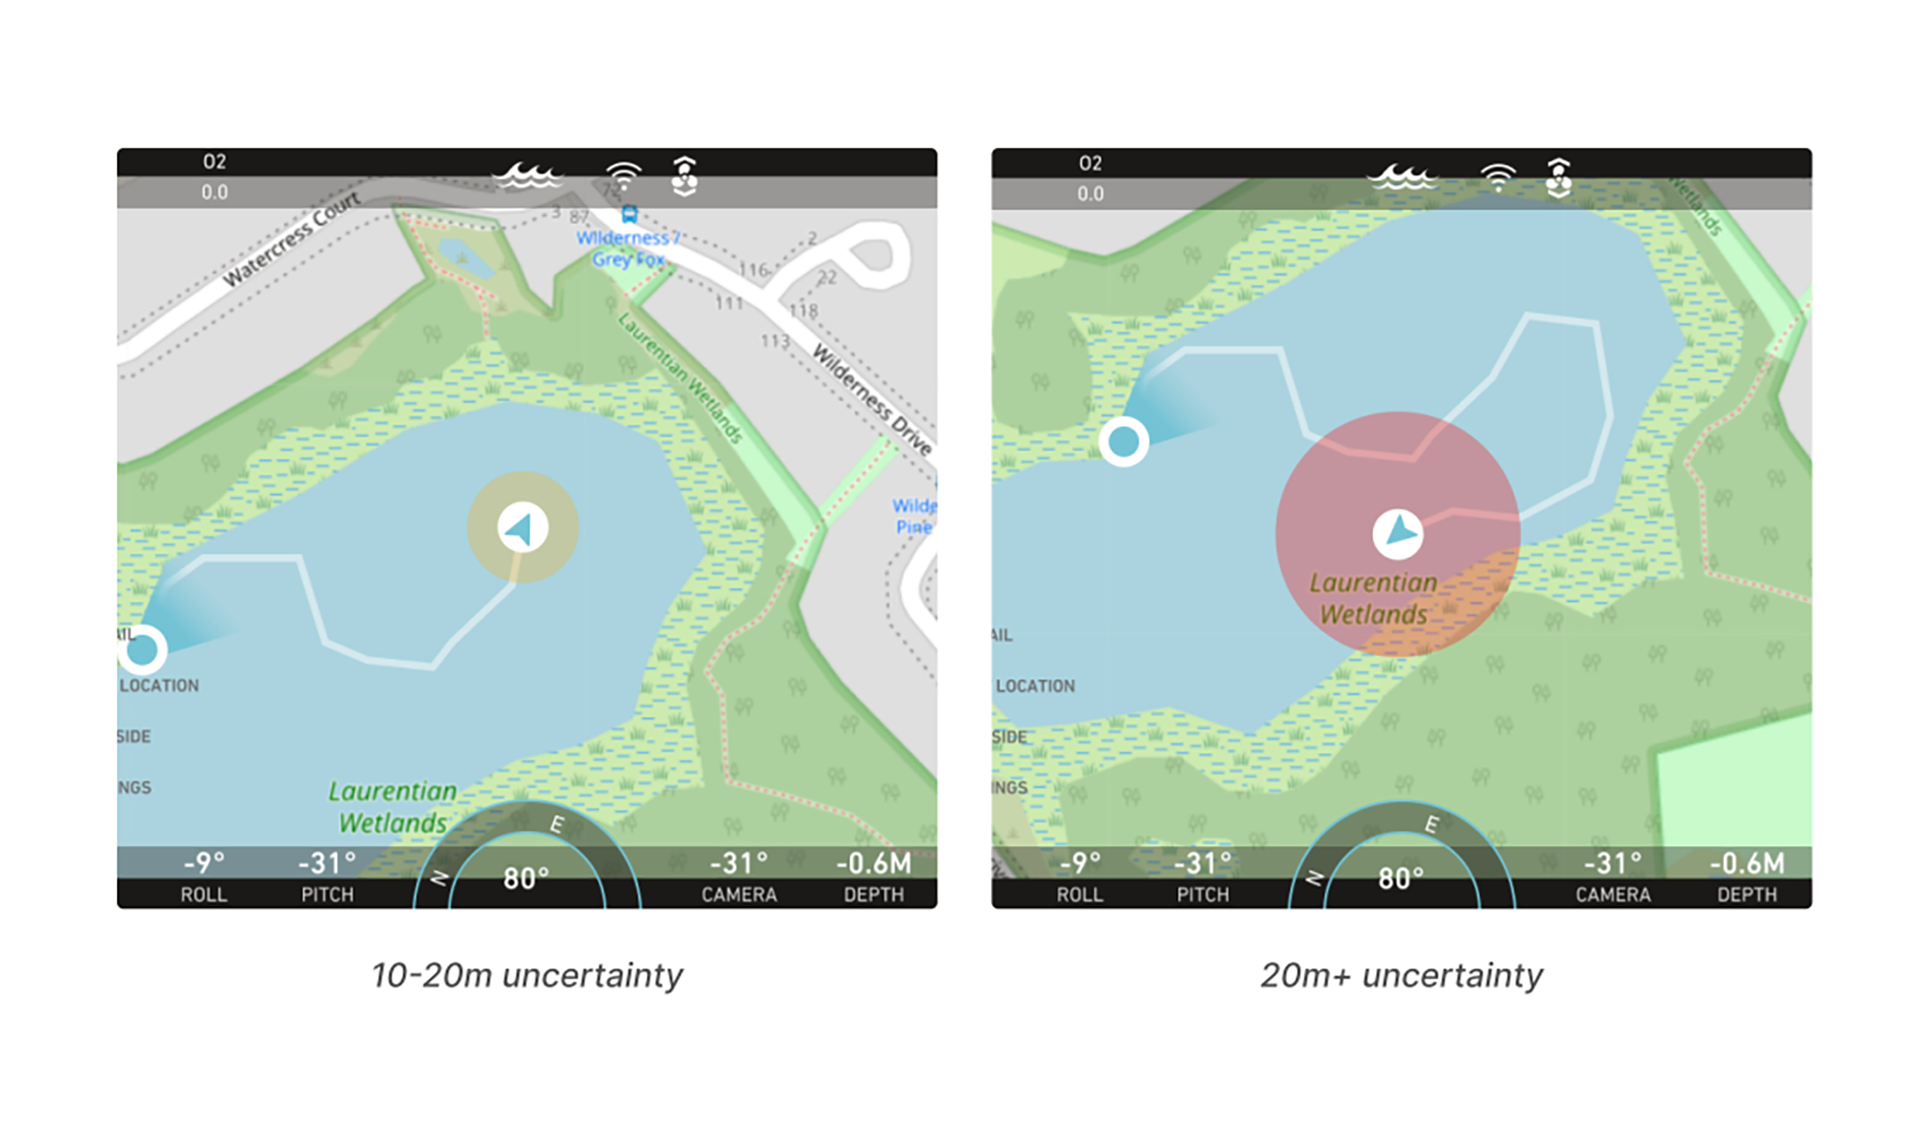
Dead Reckoning is also susceptible to disruptions caused by external factors such as ocean currents, water density variations, and submerged obstacles. These dynamic environmental conditions can impede the vehicle's trajectory, making it challenging to maintain accurate position estimates.
Additionally, reliance solely on Dead Reckoning in scenarios with limited external references, amplifies the risk of navigation errors. In such cases, a single miscalculation or sensor malfunction could lead to navigation errors with potentially serious consequences.
Addressing these challenges requires a multi-faceted approach, combining robust sensor technologies, advanced algorithms, and strategic operational practices. By continually refining Dead Reckoning systems and incorporating complementary navigation techniques, such as Deep Trekker’s Sensor Fusion algorithms, operators can navigate with greater confidence and reliability in challenging underwater environments.
Dead Reckoning is a fundamental navigation technique, offering a practical solution for navigating the intricate and often unpredictable underwater terrains encountered by ROVs (remotely operated vehicles) used for underwater operations.
Let us help find the right ROV for your underwater projects and applications
By leveraging known parameters and updating positions in responses to changes in course and speed, Dead Reckoning provides a practical means of estimating positions where traditional navigation aids may be unavailable or impractical.
Its integration with complementary technologies such as acoustic positioning systems enhances its accuracy and robustness, making it a valuable tool for underwater operations and inspection tasks.
As advancements in sensor technology and navigation algorithms continue, Dead Reckoning holds promise as a dependable navigation technique for conducting essential vessel inspections with improved precision and efficiency, even in challenging underwater environments.
Dead reckoning, also called deduced reckoning, estimates your current position from a known starting point using heading, speed, and elapsed time. Because it needs no external references, it is widely used where GPS is unavailable, including underwater, where satellite signals cannot reach.
The six rules call for updating the dead reckoning position at regular intervals, after every course change, after every speed change, after each fix or running fix, and after plotting a single line of position, then re-plotting with course and speed labelled after each fix. Together they keep the estimated position as accurate as possible between confirmed fixes.
The main factor is cumulative drift, where small sensor and estimation errors compound over time. Ocean currents, changes in water density, and frequent course or speed changes all add uncertainty, which is why regular recalibration against a fix, such as surfacing for GPS or an acoustic position update, is essential.
GPS fixes position directly from satellite signals but does not work underwater, where those signals cannot penetrate. Dead reckoning estimates position from heading, speed, and time with no external signal, so it works anywhere but drifts over time. In practice the two are combined, with an ROV surfacing or taking an acoustic update to correct its dead reckoning estimate.
Yes. Dead reckoning remains a core navigation method wherever GPS is unreliable or unavailable, including underwater robotics, aviation, and marine navigation. Modern systems automate it with inertial measurement units, Doppler velocity logs, and sensor-fusion algorithms to reduce drift.
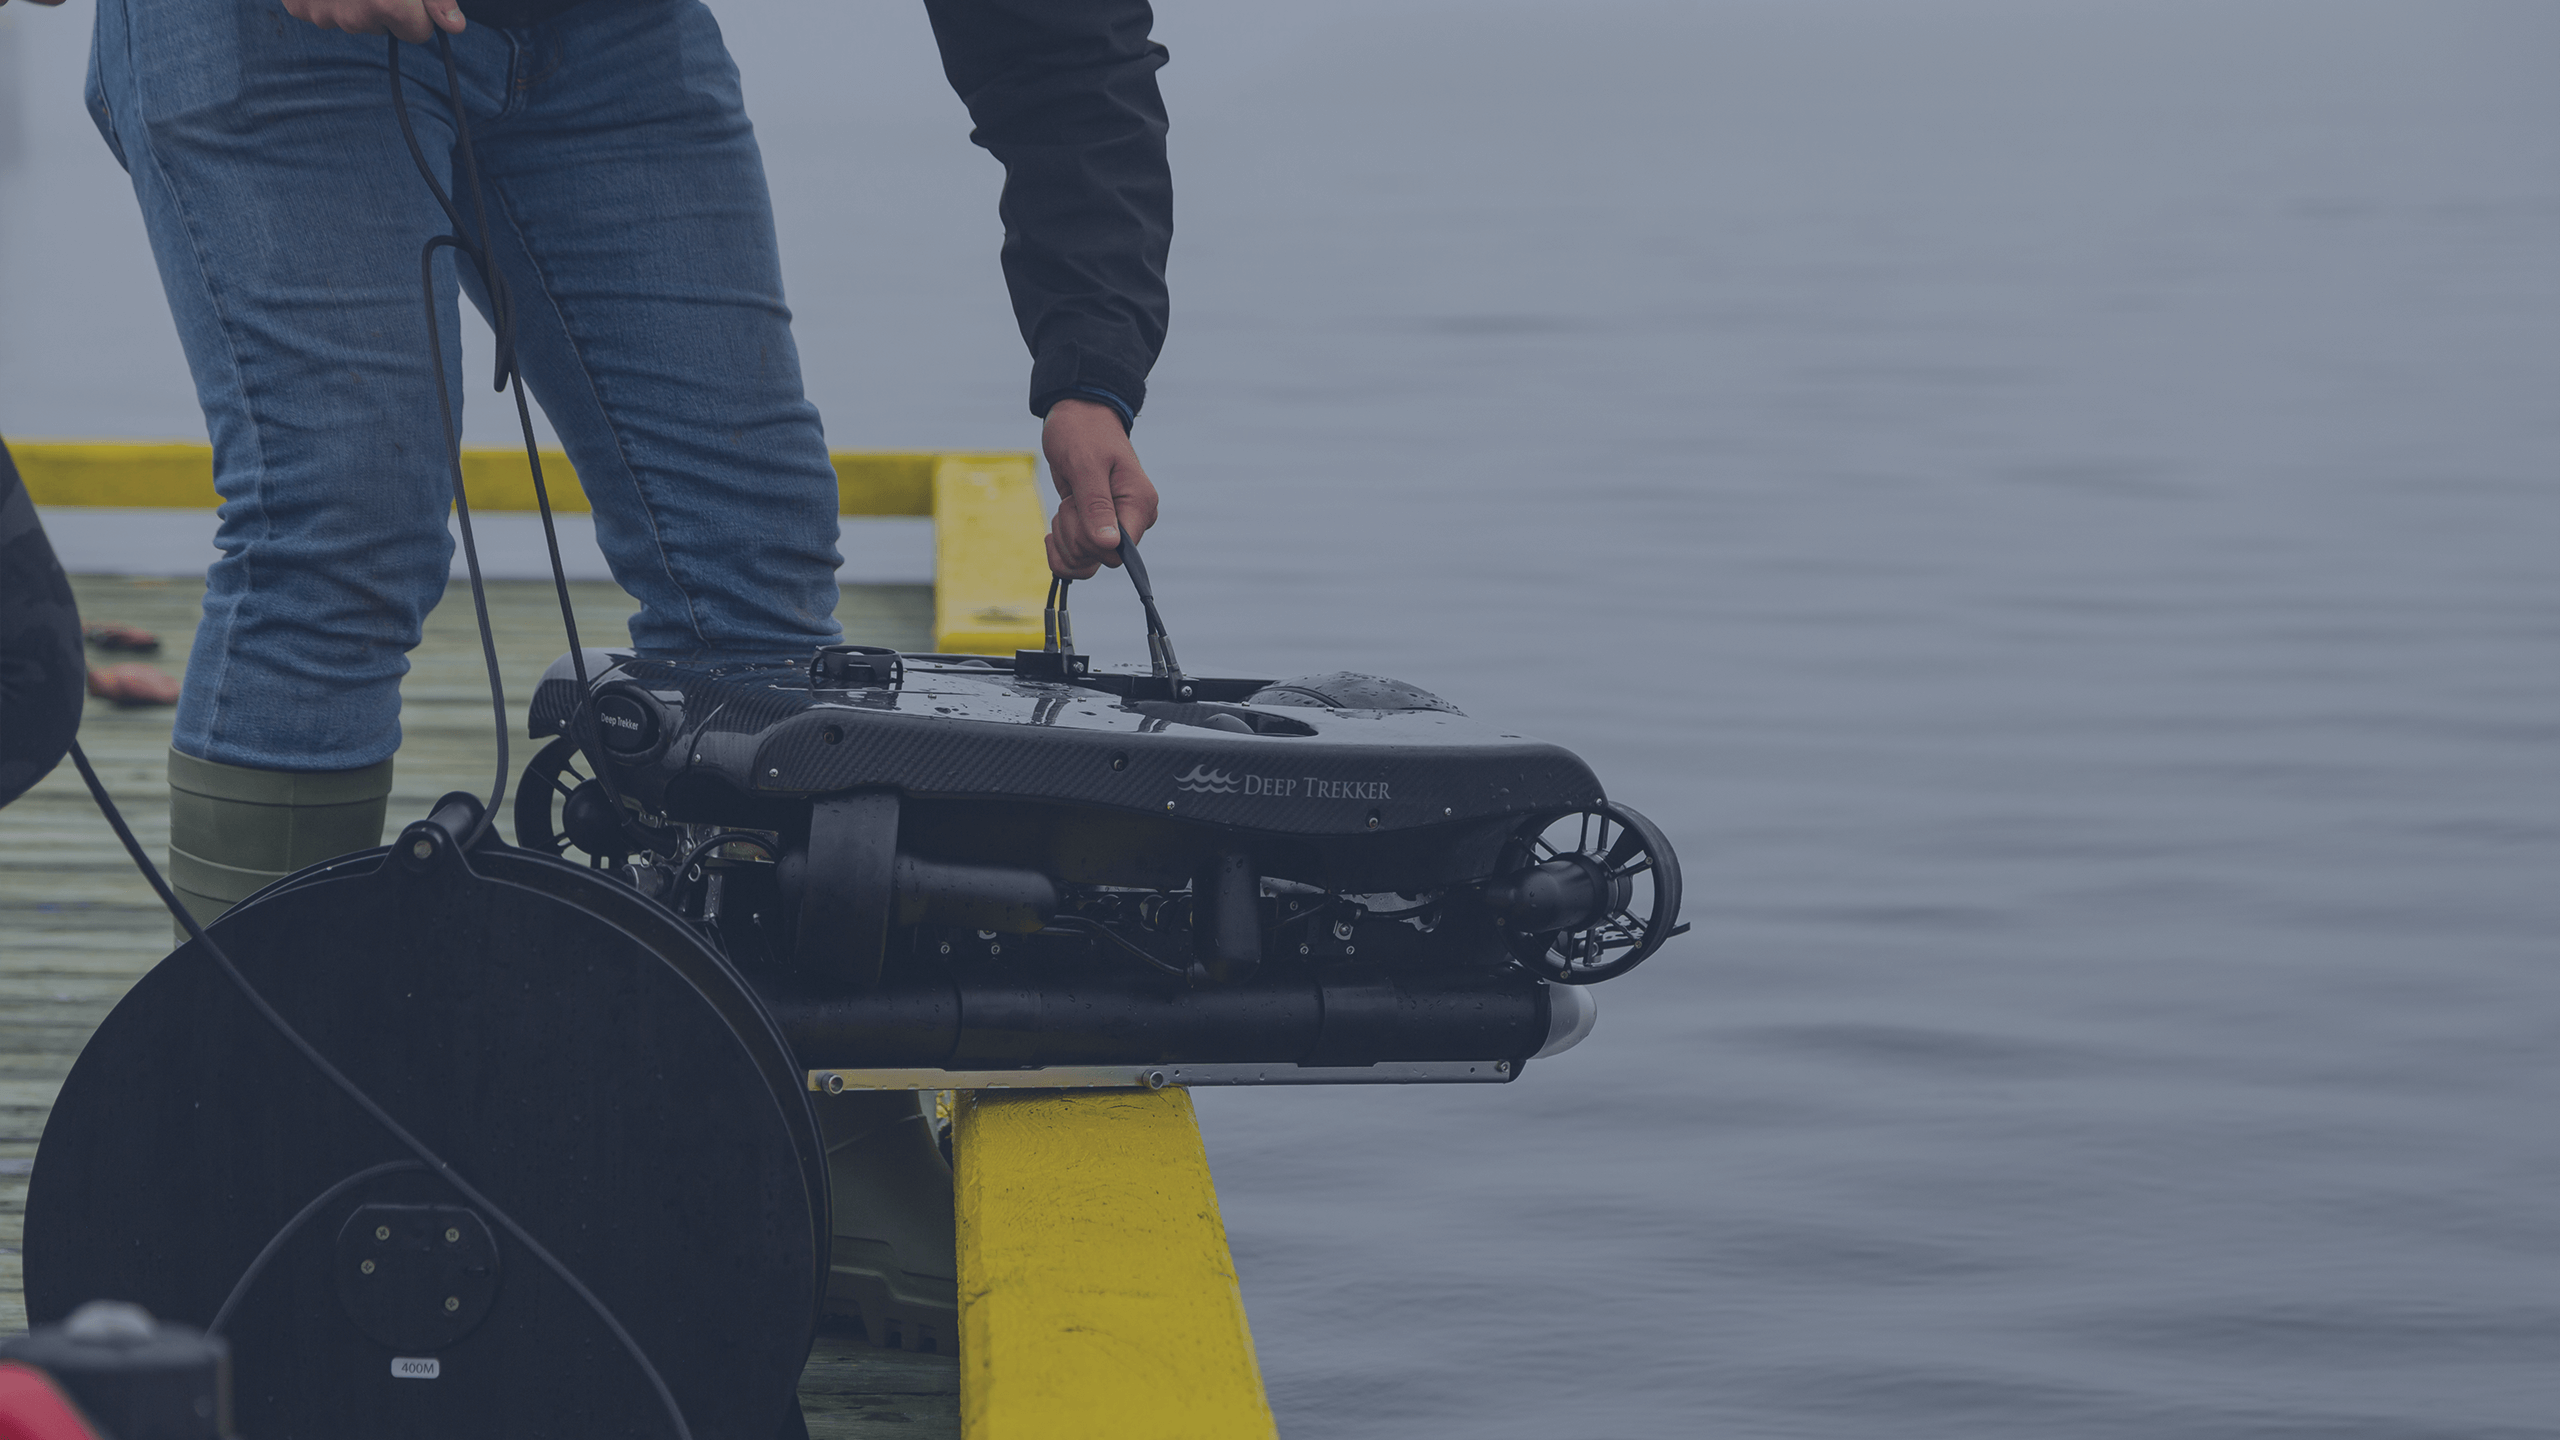
Deep Trekker ROVs, engineered with rugged industrial-grade materials, are designed for versatility and durability. They offer immediate deployment and a comprehensive variety of advanced features. These ROVs are highly portable and quick to set up, featuring powerful LED lighting, a live 4K video feed, and up to 360-degree field of view, imaging sonar, and flexible sampling tools.
Our experienced team is at your service to offer expert guidance for a wide spectrum of applications, ranging from inspecting hull vessels to water tanks to conducting underwater assessments across various industries. We ensure tailor-made solutions that precisely match your specific requirements. When you're prepared to acquire your Deep Trekker underwater ROV, don't hesitate to get in touch with us for a personalized quote.
July 3rd, 2026
Everything you need to become an ROV pilot: what the job...
September 1st, 2026
Compare imaging, side scan, echosounder, and 3D sonar systems for underwater...
December 23rd, 2021
ROVs and sonar can be used to inspect underwater structures such...