Configure Now
Items in Your Cart0
0Items in Your Cart
Start building your packageShop Now
Remotely operated vehicles (ROVs) support offshore operations across oil and gas, offshore wind, and marine construction. They inspect, monitor, and document submerged assets, and they handle light repair and maintenance tasks between larger interventions.
This guide covers how ROVs are used offshore, where they fit in subsea remedial work, how a platform inspection is planned, and how portable systems are deployed. It also covers where SPECTRA, built for offshore Inspection, Repair, and Maintenance (IRM), fits into those scopes.
Recommended Article: Industries Benefiting from Remotely Operated Underwater Vehicles (ROVs)
What began in the 1980s as a small fleet serving industrial and military operations now runs across the offshore sector. Operators increasingly build ROVs into routine inspection and maintenance programmes, reflecting a shift toward remote and assisted inspection methods.
Offshore assets are complex, hazardous, and costly to manage. Regular inspection catches corrosion, damage, and leaks before they escalate into failures with safety and environmental consequences.
ROVs reduce the need for scaffolding, sky-lifts, cherry pickers, and helicopter surveys. They also limit how often inspectors dive in hazardous conditions or work at height and in confined spaces, such as ballast tanks.

Oil platforms are engineered to withstand extreme temperatures and pressures. They need routine inspection to confirm structural integrity and to catch rust, corrosion, and other hazards early.
Underwater ROVs can inspect a wide range of platform assets, including:
With regular ROV inspection, operators can monitor for leaks, limit environmental impact, and respond quickly when conditions change.
Confined and flooded spaces such as ballast tanks and cooling systems are where positioning matters most. SPECTRA uses real-time Sonar SLAM to stay localized inside these structures, where GNSS is unavailable and visibility is often limited.
For a wider view of inspection scopes across the sector, see our offshore wind, oil, and gas capabilities.
Offshore pipelines run long distances across the seabed, and risers connect them to the platforms above. Both are exposed to corrosion, impact damage, free spans, and marine growth, so they need regular monitoring.
An inspection-class ROV can follow a riser from the splash zone to touchdown, or track a pipeline or export cable to check burial, scour, and coating condition. A small team can mobilize and complete a targeted survey within hours.
Mooring chains and connectors get the same treatment, with close visual inspection for wear, corrosion, and marine growth along the chain and at the touchdown point. Our guide to ROV pipeline inspections covers survey methods in more detail.

Floating Production Storage and Offloading (FPSO) units process and store oil and gas offshore, often for years without returning to port. That makes in-water inspection the practical alternative to dry-docking.
ROVs carry out underwater hull inspections in Lieu of Dry-Docking (UWILD), checking for biofouling, cracks, structural defects, corrosion, and coating condition. They also reach rudders, propellers, sea chests, and ballast tanks.
Sea chests, ballast tanks, and hull plating are typical SPECTRA scopes. Photogrammetry output supports coating condition assessment and defect measurement that can be compared directly between campaigns.
See how CAN Group inspected FPSO ballast tanks without draining them.
Drilling support on deepwater rigs has long been work-class ROV territory, with large vehicles monitoring blowout preventers, wellheads, and riser connections throughout a campaign. Smaller ROVs add value around that core work.
Before drilling, ROVs survey and sample the seafloor to assess a new site. They map terrain, identify hazards and debris, and collect sediment samples that help geologists judge whether a location is viable.
During operations, portable ROVs can handle general visual checks around wellheads, subsea structures, and the seabed. Orange Force Marine, for example, used a Deep Trekker ROV to build a 3D model of a submerged wellhead, covered in the case studies below.
ROVs verify site conditions before divers enter the water and monitor dive teams throughout an operation. During installation of equipment, pipelines, and cables, they confirm placement and attachment and give the surface team a live view of the work site.
In one recent deployment, an ROV provided real-time monitoring of HDD punch-out during a subsea cable landing on Guam, confirming position and seabed condition as the operation progressed.

Offshore wind is scaling fast. The Global Wind Energy Council forecasts global capacity rising from 83 GW in 2024 to roughly 238 GW by 2030, and the IEA's Renewables 2025 report puts its main case at 224 GW.
Every one of those turbines sits on a foundation that needs periodic subsea inspection. Monopiles, jacket structures, scour protection, J-tubes, and inter-array cables all sit in exposed water with narrow weather windows.
ROVs survey foundations and cable routes for corrosion, coating breakdown, marine growth, and scour without mobilizing a dive team or a jack-up. Regular, repeatable surveys support planned maintenance and reduce how often people need to access hazardous areas.
Monopile and scour protection inspection is unforgiving work. The steel is curved, the rock berm at the base is sloped, and the current rarely waits for a convenient window.
SPECTRA answers that with true six-axis control. It does not just hold depth and heading. It holds an attitude.
Pitch the vehicle to sit square against a sloping berm or a curving monopile face and it stays pinned there, camera normal to the surface, while the current runs past.
The inspection follows the geometry of the asset instead of fighting it, and the workable window opens well past slack water.
Offshore energy production can affect marine ecosystems, and faulty equipment can cause lasting damage. Regular inspection lets operators find leaks, cracks, corrosion, and spills early and address them before they spread.
ROVs also support environmental surveys by evaluating species and habitats, collecting water and sediment samples, analyzing water quality, and surveying the seafloor.
They help recover ghost fishing gear, the lost or discarded equipment that continues to harm marine life. Hull inspections also help limit the spread of invasive species carried by commercial shipping.
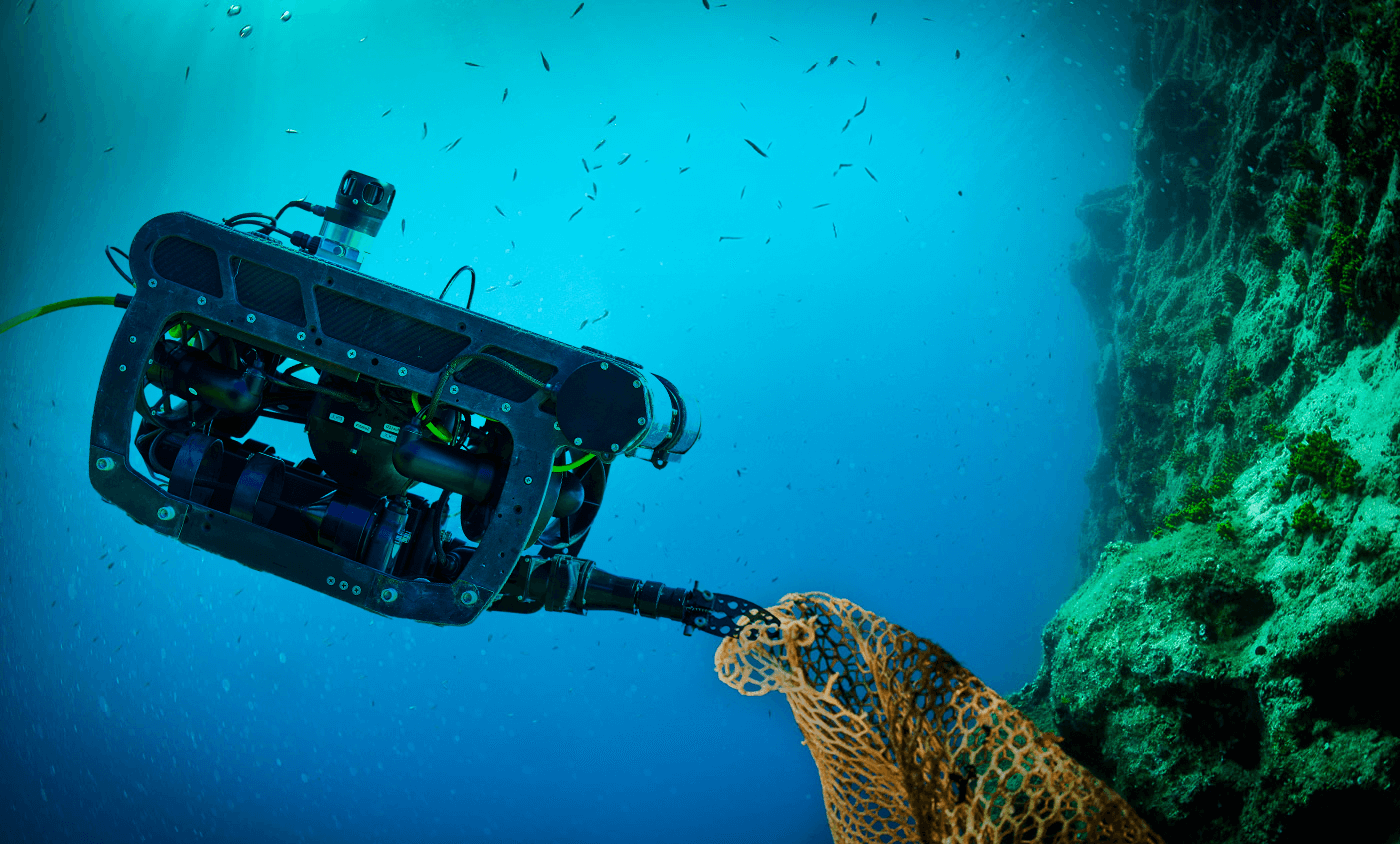
ROVs help locate and, where possible, recover missing people, vessels, aircraft, and equipment. Cameras and sonar keep a search moving in conditions that limit traditional methods, and recorded footage documents the scene for investigators.
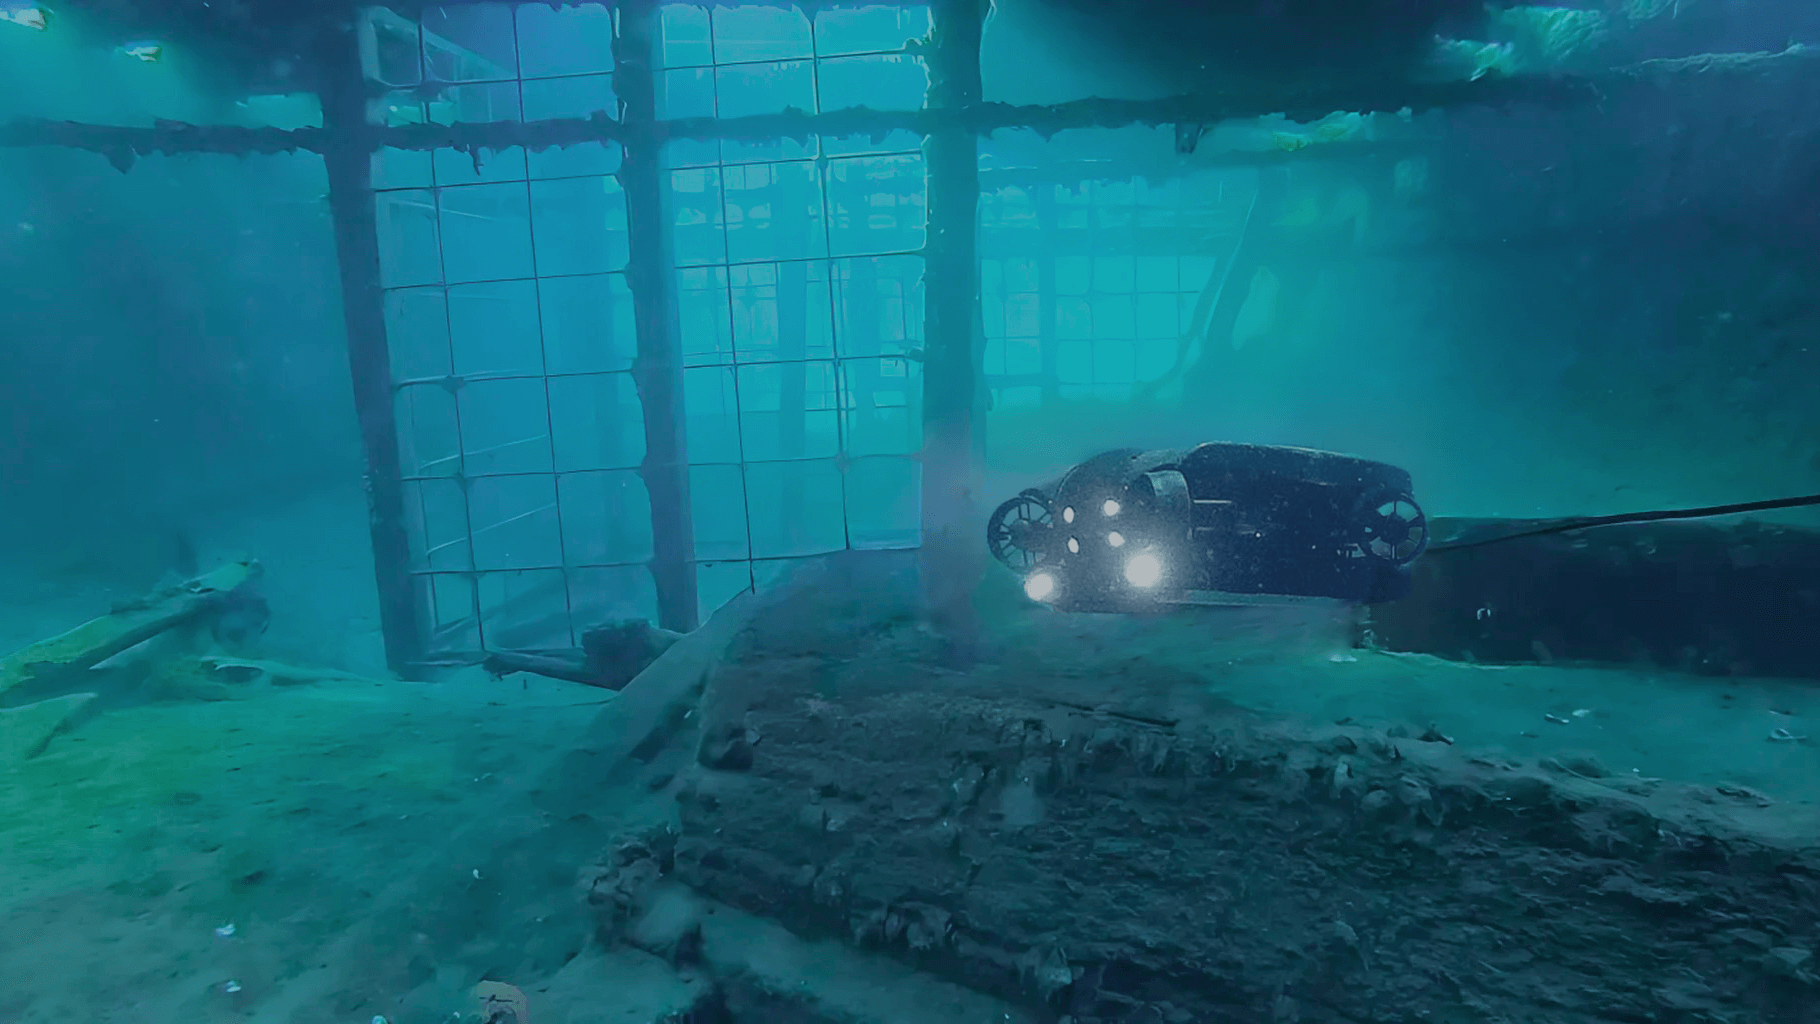
The same capabilities apply to maritime archaeology. ROVs document shipwrecks and submerged sites that are too deep or hazardous for regular access, and photogrammetry turns those images into 3D models that track condition over time.
On SPECTRA, this runs alongside 3D Sonar SLAM, so a site can be modelled and localized in the same pass.
Subsea remedial work is the corrective action that follows an inspection finding: cleaning, repairing, stabilizing, or replacing a component so the asset returns to specification. It is the repair in Inspection, Repair, and Maintenance (IRM).
ROVs support remedial work at every stage. Before a repair, they confirm the extent of the defect and collect the data needed to plan it. Afterward, they verify the fix and record a new baseline for the next campaign.
Inspection-class ROVs equipped with the right manipulators and tools handle a range of light remedial tasks directly:
Heavier remediation, such as clamp installation or high-torque valve work, remains work-class territory. Handling the survey and light intervention with a portable system reduces how often a work-class spread needs to be mobilized and keeps it focused on the tasks only it can do.
An offshore platform ROV inspection follows a defined procedure: plan the scope, check conditions and equipment, fly the survey, and report findings against acceptance criteria. The checklist below outlines the typical stages.
Requirements vary by operator, regulator, and class society, so use this checklist alongside your own procedures rather than in place of them.
Offshore ROV deployment depends on the size of the vehicle. Work-class systems need a dedicated support vessel, a launch and recovery system (LARS) such as an A-frame or crane, a tether management system, and a crew working in shifts.
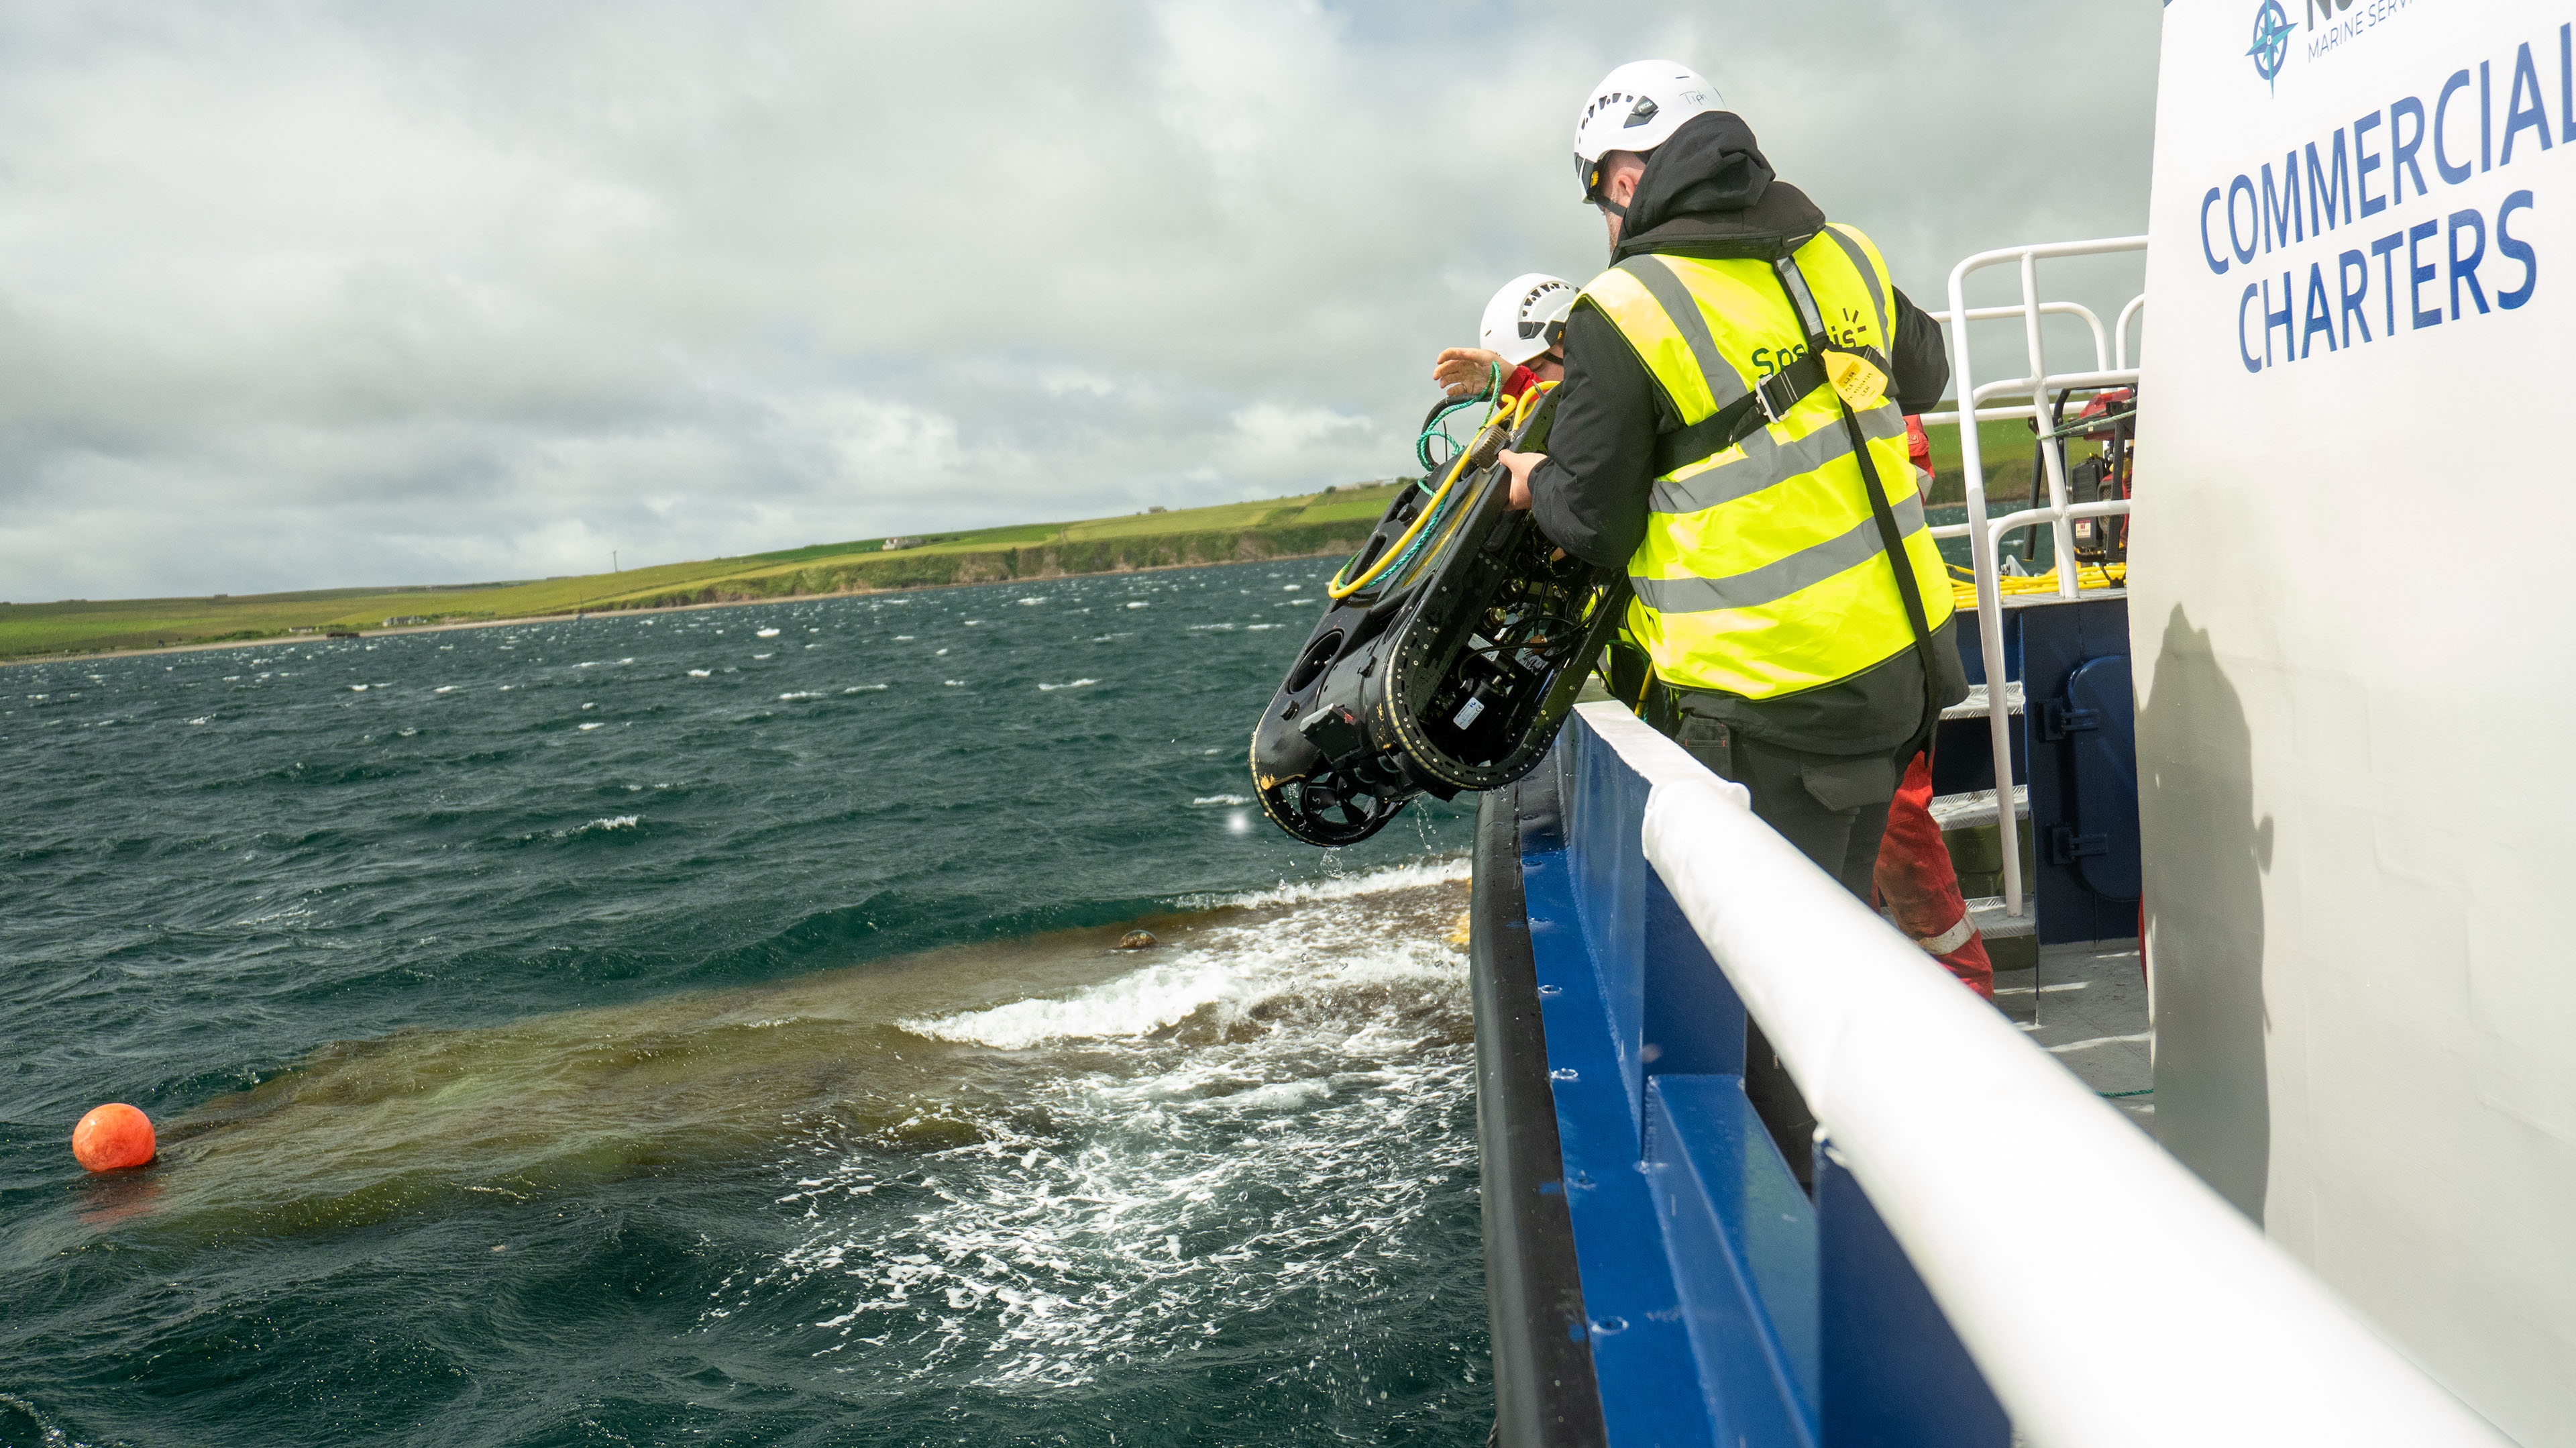
Portable inspection-class ROVs deploy by hand. A two-person team can launch from a platform deck, an FPSO, a vessel of opportunity, or the quayside, managing the tether from a reel at the surface.
That difference shapes response time. A portable system can travel with the crew and go into the water once the scope is confirmed, without waiting for a vessel slot or crane availability.
Hand deployment holds even at the upper end of the range. SPECTRA weighs 38 kg (84 lbs) in air and is rated to 1,000 m (3,280 ft).

ROVs make offshore inspection faster, safer, and more affordable than methods that rely on access equipment, dry-docking, or extended dive operations. Key benefits include:
Miko Marine AS, headquartered in Oslo, Norway, used Deep Trekker ROVs on a marine salvage project for an offshore drilling company. Miko designed cofferdam and sea chest covers that use magnetic adhesion to improve seal integrity.
Each cover used four Miko MAM permanent magnets, each holding up to 450 kg, to create an immediate watertight seal without additional fasteners.

The covers were deployed off Haugesund, Norway, at a depth of 16 meters. An inspection ROV assessed the covers externally while an internal camera confirmed there was no leakage.
Miko Marine also explained that, "When the job is finished, each magnet is simply freed by having its release lever lifted by a diver or ROV, so the cofferdam can then be retrieved."
Orange Force Marine Ltd. used a Deep Trekker ROV to build a 3D photogrammetry model of a submerged wellhead for a client. The ROV captured high-resolution images from multiple angles, which were processed into a detailed model.

Derek Niles, President at Orange Force Marine Ltd., remarked, "The clarity and stability of the ROV's footage were crucial in capturing the necessary data for an accurate model."
The model gave Orange Force Marine and its client a full view of the wellhead's condition, supporting inspection, analysis, and maintenance planning without divers.
Derek highlighted the benefits, stating,
"The precision of the Deep Trekker ROV allowed us to generate a model that exceeded our expectations, providing invaluable insights into the wellhead's structural integrity."
The team also valued the vehicle's handling. "The ROVs intuitive controls and rugged design made it an indispensable tool for our operation," Derek added.
SPECTRA is Deep Trekker's inspection-class ROV built for offshore Inspection, Repair, and Maintenance (IRM) scopes. It holds position in moving water, operates to 1,000 m (3,280 ft), and carries integrated NDT tooling alongside real-time 3D mapping.
That combination brings a significant share of typical IRM work within reach of a system a small team can mobilize from a single case.

Platform legs, risers, and mooring points sit in moving water, and current is the most common reason an inspection window closes. Seven thrusters, four vectored and three vertical, produce 40 kg (88 lbs) of thrust.
SPECTRA is rated to 3.5 knots forward and holds station in currents up to 2.3 knots from any direction. Crews can work tidal windows that would otherwise be stood down and complete a survey pass rather than repeat it.
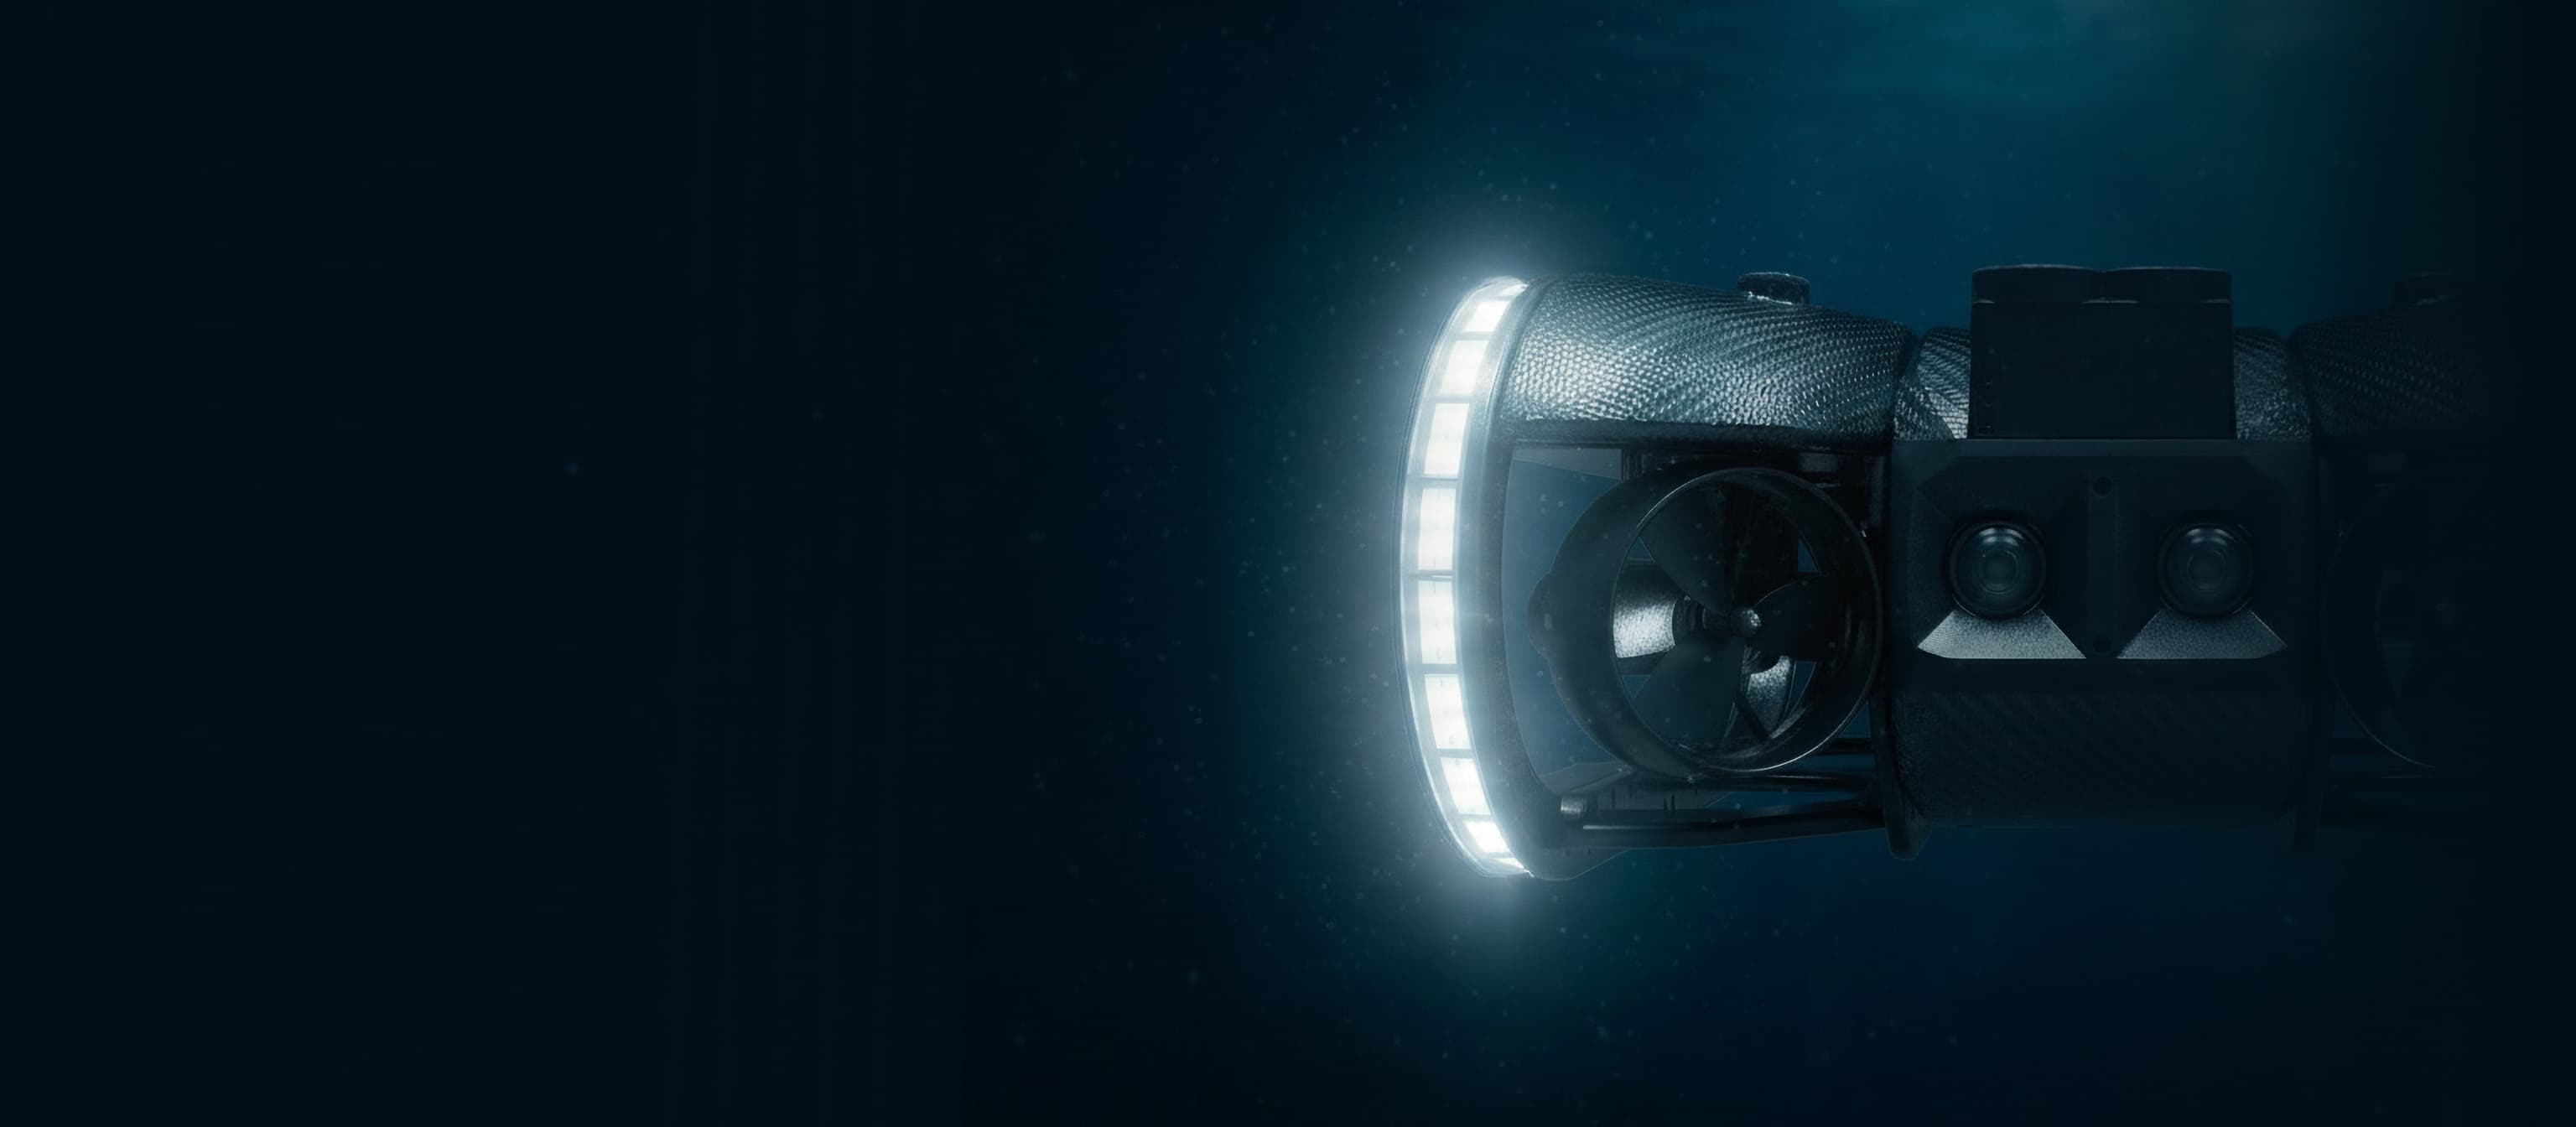
A rotating 4K stereo camera and a dual 150,000 lumen continuous LED light frame with camera tracking handle the optical side of an inspection. Where turbidity defeats cameras, 180 degree 2D imaging and 3D sonar carry the work instead.
Real-time Sonar SLAM maintains position and mapping in GNSS-denied conditions, such as under a hull, inside a ballast tank, or alongside subsea structures.
Sonar SLAM and photogrammetry combine to produce 3D models of the asset. Instead of a report that references video timecodes, integrity engineers receive measurable geometry.
That means defect sizing, change detection between campaigns, and asset visualization that can be shared with stakeholders who were never on the vessel.

Serviceability offshore matters as much as capability. SPECTRA supports modular field servicing in under 30 minutes and ships with a 300 m fibre tether, with kilometre-plus options for scopes to the full 1,000 m rating.
The system travels in an SKB iSeries case and runs on 100 to 260 VAC, which suits vessel and platform power without dedicated infrastructure.

SPECTRA is the right fit when the scope involves current, depth, or deliverables beyond inspection video. For lighter or more confined work, the next section covers where PHOTON, PIVOT, and REVOLUTION fit.
Explore SPECTRA specifications or speak with an offshore specialist about your next campaign.
Deep Trekker ROVs are built for quick deployment, precise control, and harsh conditions. The right choice depends on depth, payload, confinement, and current.
PHOTON is a lightweight mini observation-class ROV for confined and hard-to-reach spaces. It is rated to 120 meters and carries an ultra-high-definition camera with a rotating head, LED floodlights, and tether options up to 300 meters.
PIVOT and REVOLUTION add payload capacity, greater depth, and modular options such as sonar imaging. Both are rated to 305 meters (1,000 ft).
Six vectored thrusters give both vehicles stable, precise maneuverability. They carry intelligent sensors, a 200-degree rotating 4K camera head, BRIDGE integration, and modular tool add-ons for a wide range of offshore tasks.
For a side-by-side look at depth, payload, and deployment, see the ROV Buying Guide.
As ROVs become part of routine offshore programmes, ROV pilot and ROV supervisor have become established career paths rather than niche specialisms. Demand for those skills has grown with adoption of the technology.
Portable systems also widen who operates them, from inspection contractors to dive teams and asset owners' own technicians. That puts a premium on structured training and repeatable procedures.
Deep Trekker offers hands-on ROV training courses for teams bringing ROVs into their programmes. For training routes, certification, and current salary data, see our guide on how to become an ROV pilot.
Deep Trekker ROVs are built from industrial-grade materials, including stainless steel, anodized machined aluminum, and carbon fiber, for reliable work in harsh offshore conditions.
Our team of industry professionals can provide expert guidance on bringing ROVs into your inspection, repair, and maintenance programme. When you are ready, request a customized quote.

March 17th, 2026
Two-day AIMS training program teaches SAR teams how to integrate sonar...
March 11th, 2026
Deep Trekker’s SPECTRA ROV integrates 3D Sonar SLAM, 4K stereo vision,...
November 3rd, 2025
At REPMUS 2025, Deep Trekker’s ROVs validated real-world mine countermeasure capabilities...